Research Output
Publications
Selected journal articles, conference papers, and thesis work in robotics, perception, and autonomous systems.
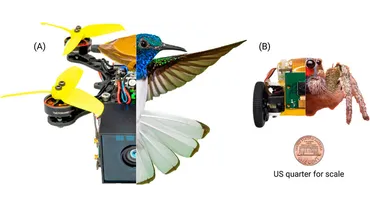
Minimal perception: enabling autonomy in resource-constrained robots
Frontier Robotics · Sep 2024
Frontier Robotics AI, 17 September 2024 | Robot Vision and Artificial Perception
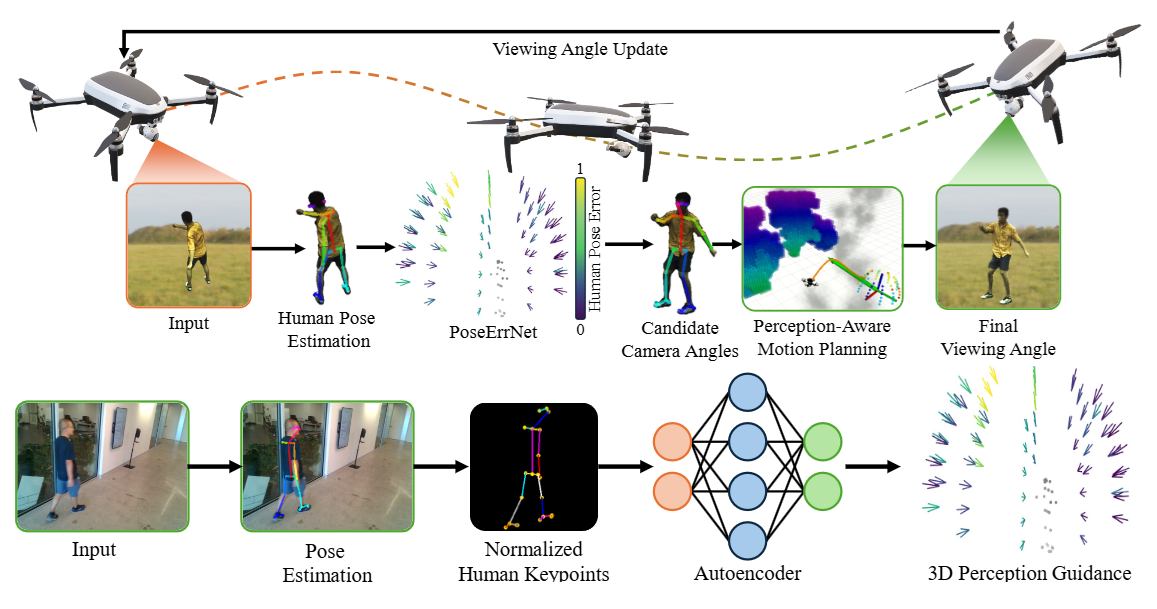
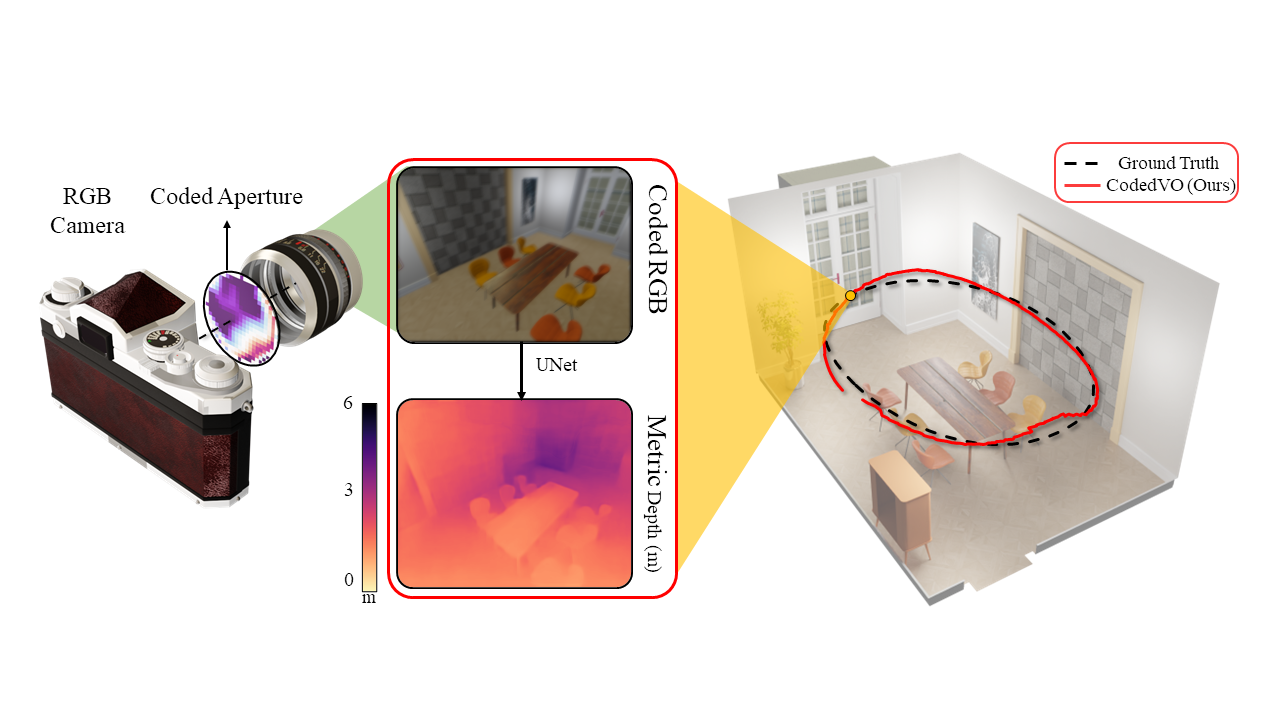
CodedVO: Coded Visual Odometry
RA-L 2024
IEEE Robotics and Automation Letters (RA-L), 2024
* Equal contribution; † Equal contribution.
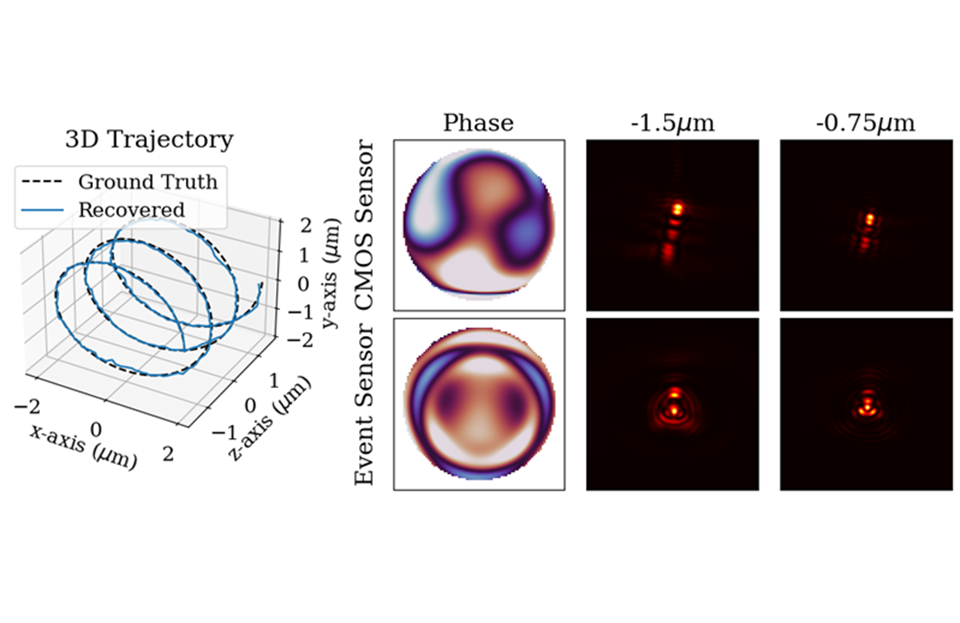
CodedEvents: Optimal Point Spread Function Engineering for 3D-Tracking with Event Cameras
CVPR 2024
Conference on Computer Vision and Pattern Recognition (CVPR)
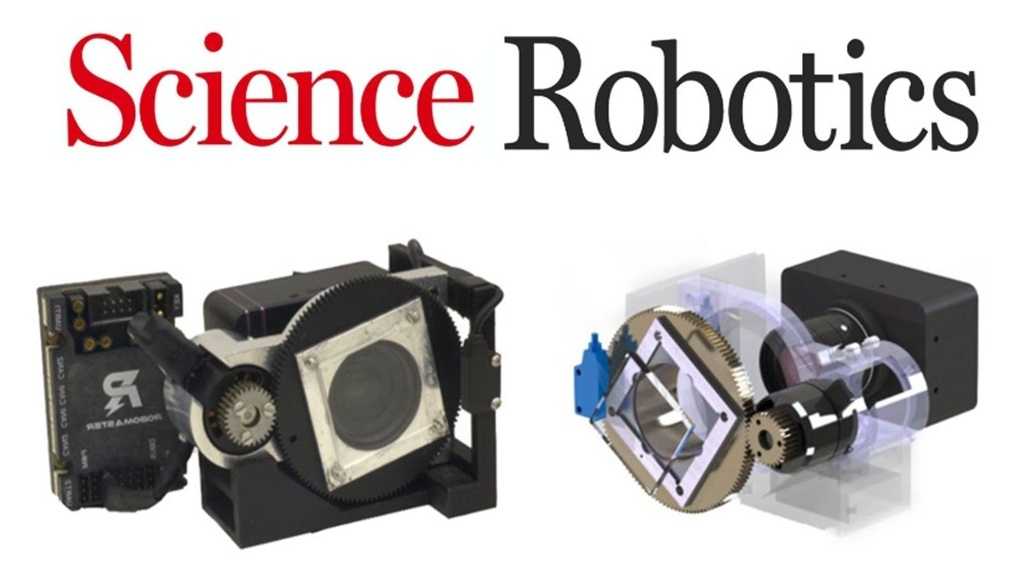
Microsaccade-inspired event camera for robotics
Science Robotics · Jun 2024
Science Robotics | AAAS Volume 9, 2024
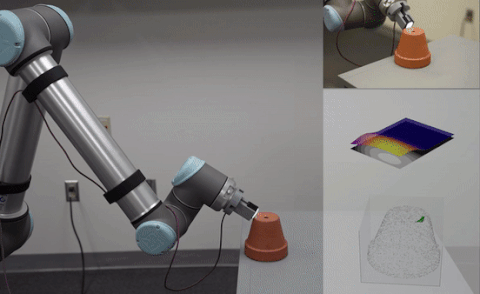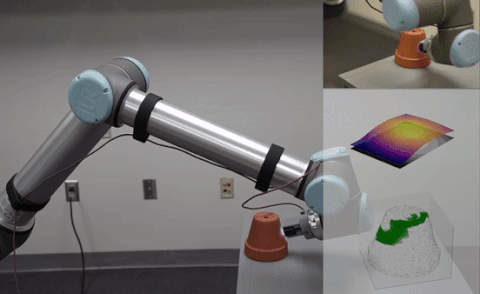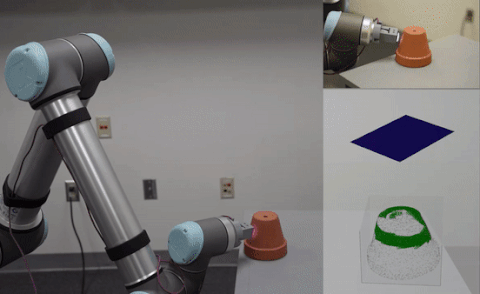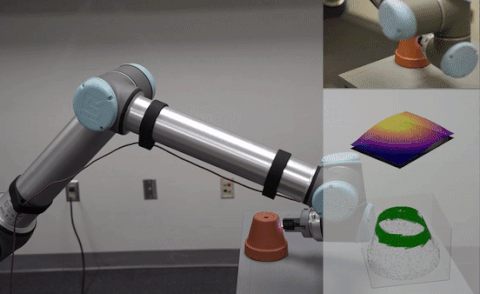
AcTExplore: Active Tactile Exploration on Unknown Objects
ICRA 2024
IEEE International Conference on Robotics and Automation (ICRA)
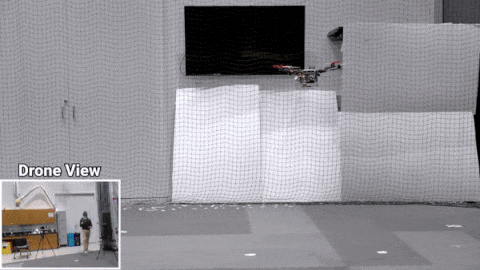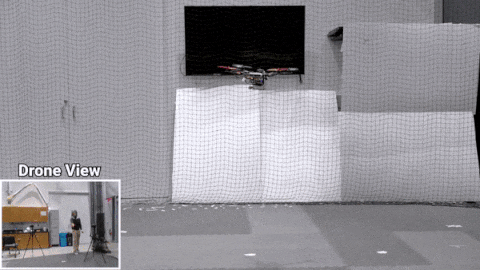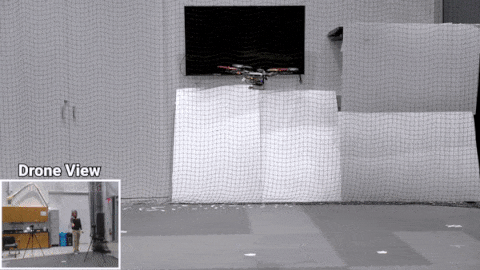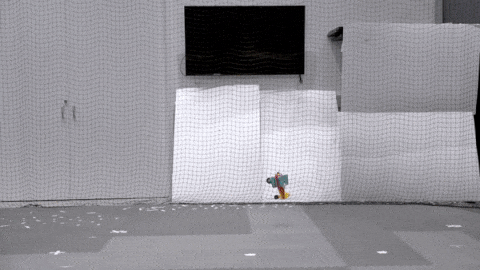
Ajna: Generalized Deep Uncertainty for Minimal Perception On Parsimonious Robots
Science Robotics (Cover) · Aug 2024
Science Robotics | AAAS Volume 8, Issue 81, 2023
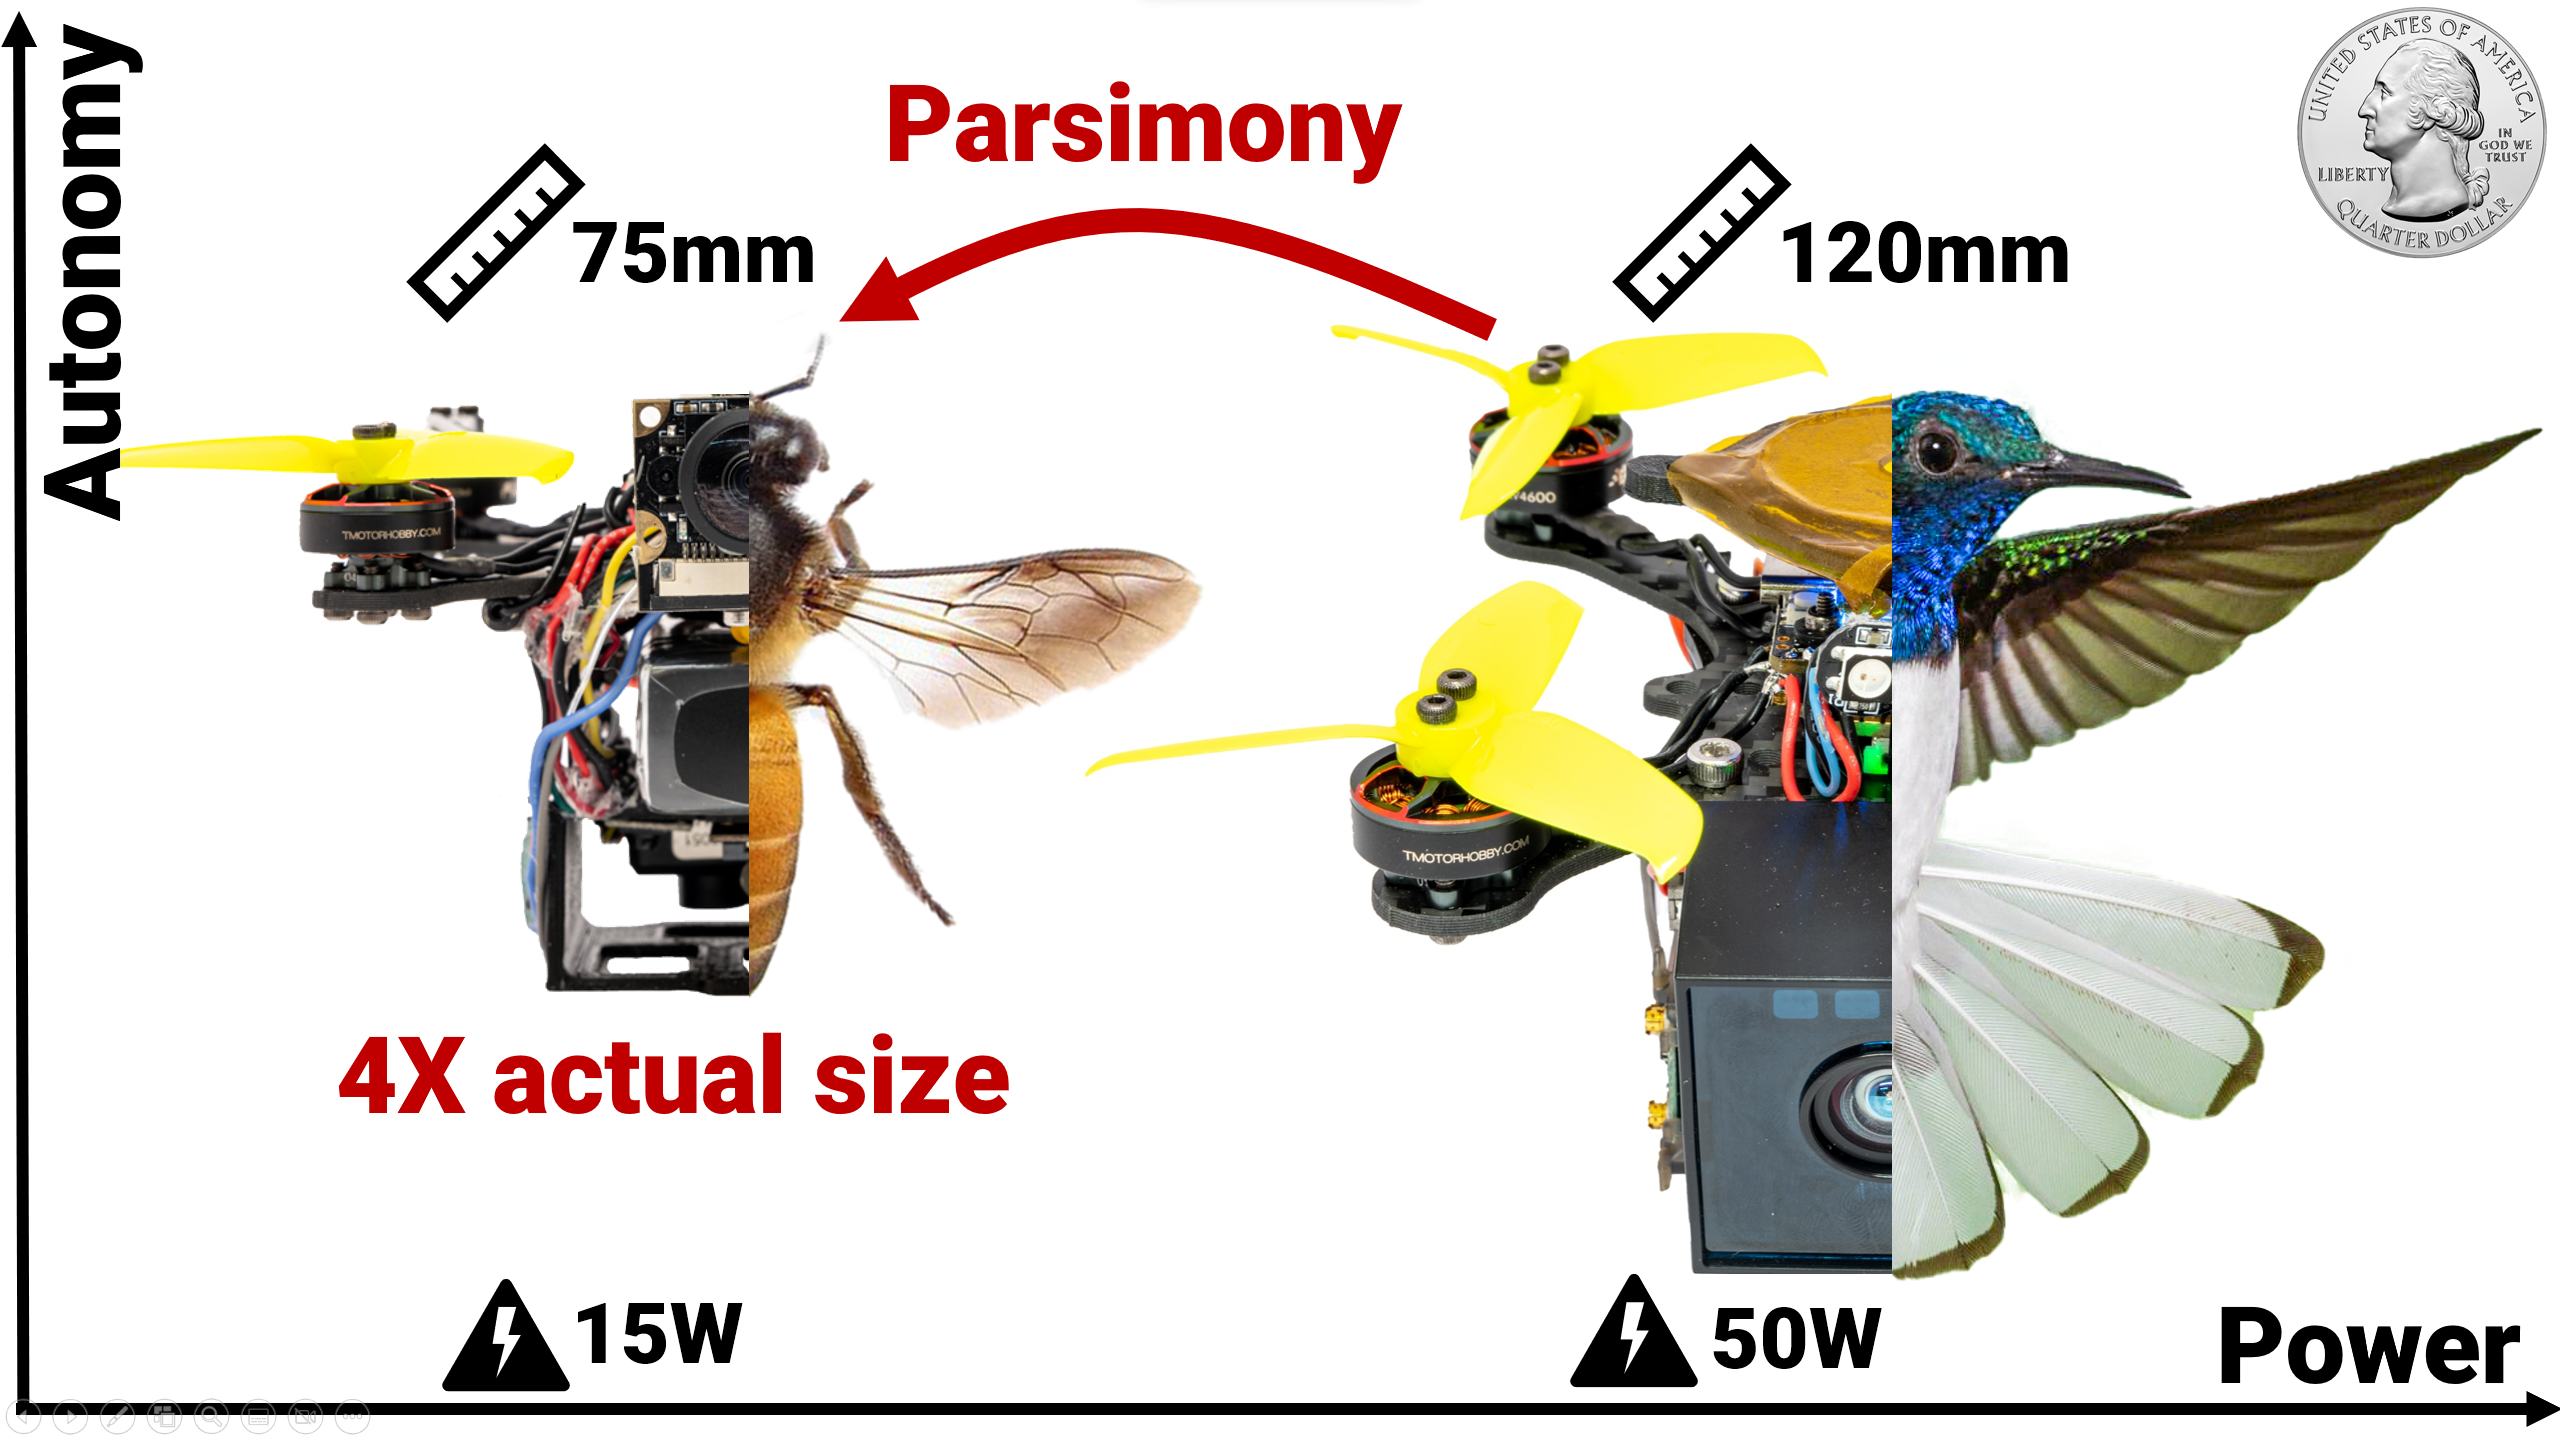
Minimal Perception: Enabling Robot Autonomy on Resource-Constrained Robots
UMD Thesis · Jun 2023
University of Maryland, College Park
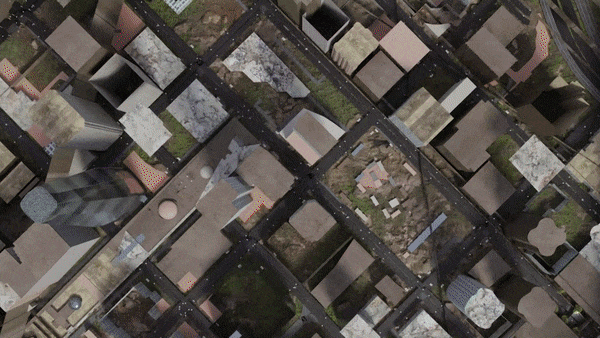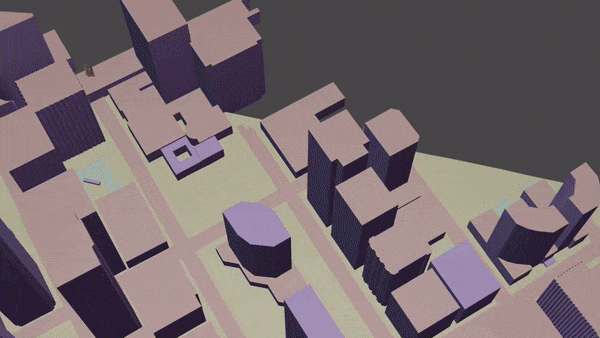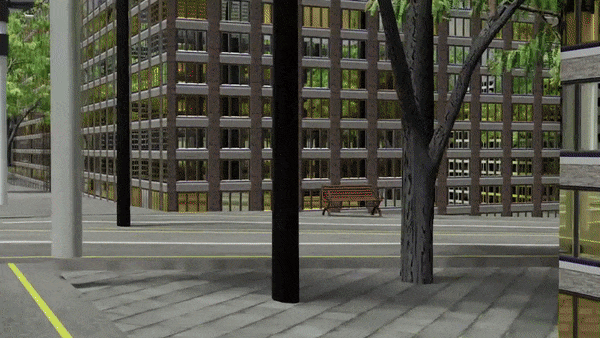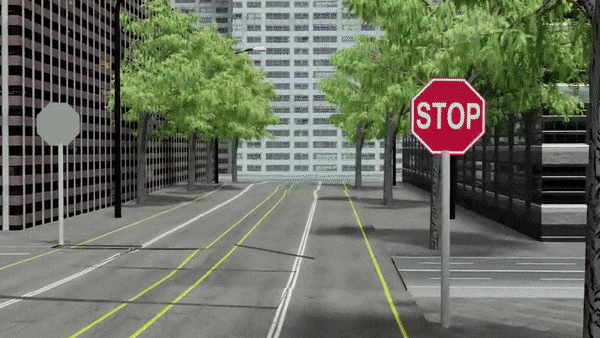
WorldGen: A Large Scale Generative Simulator
ICRA 2023
IEEE International Conference on Robotics and Automation (ICRA)
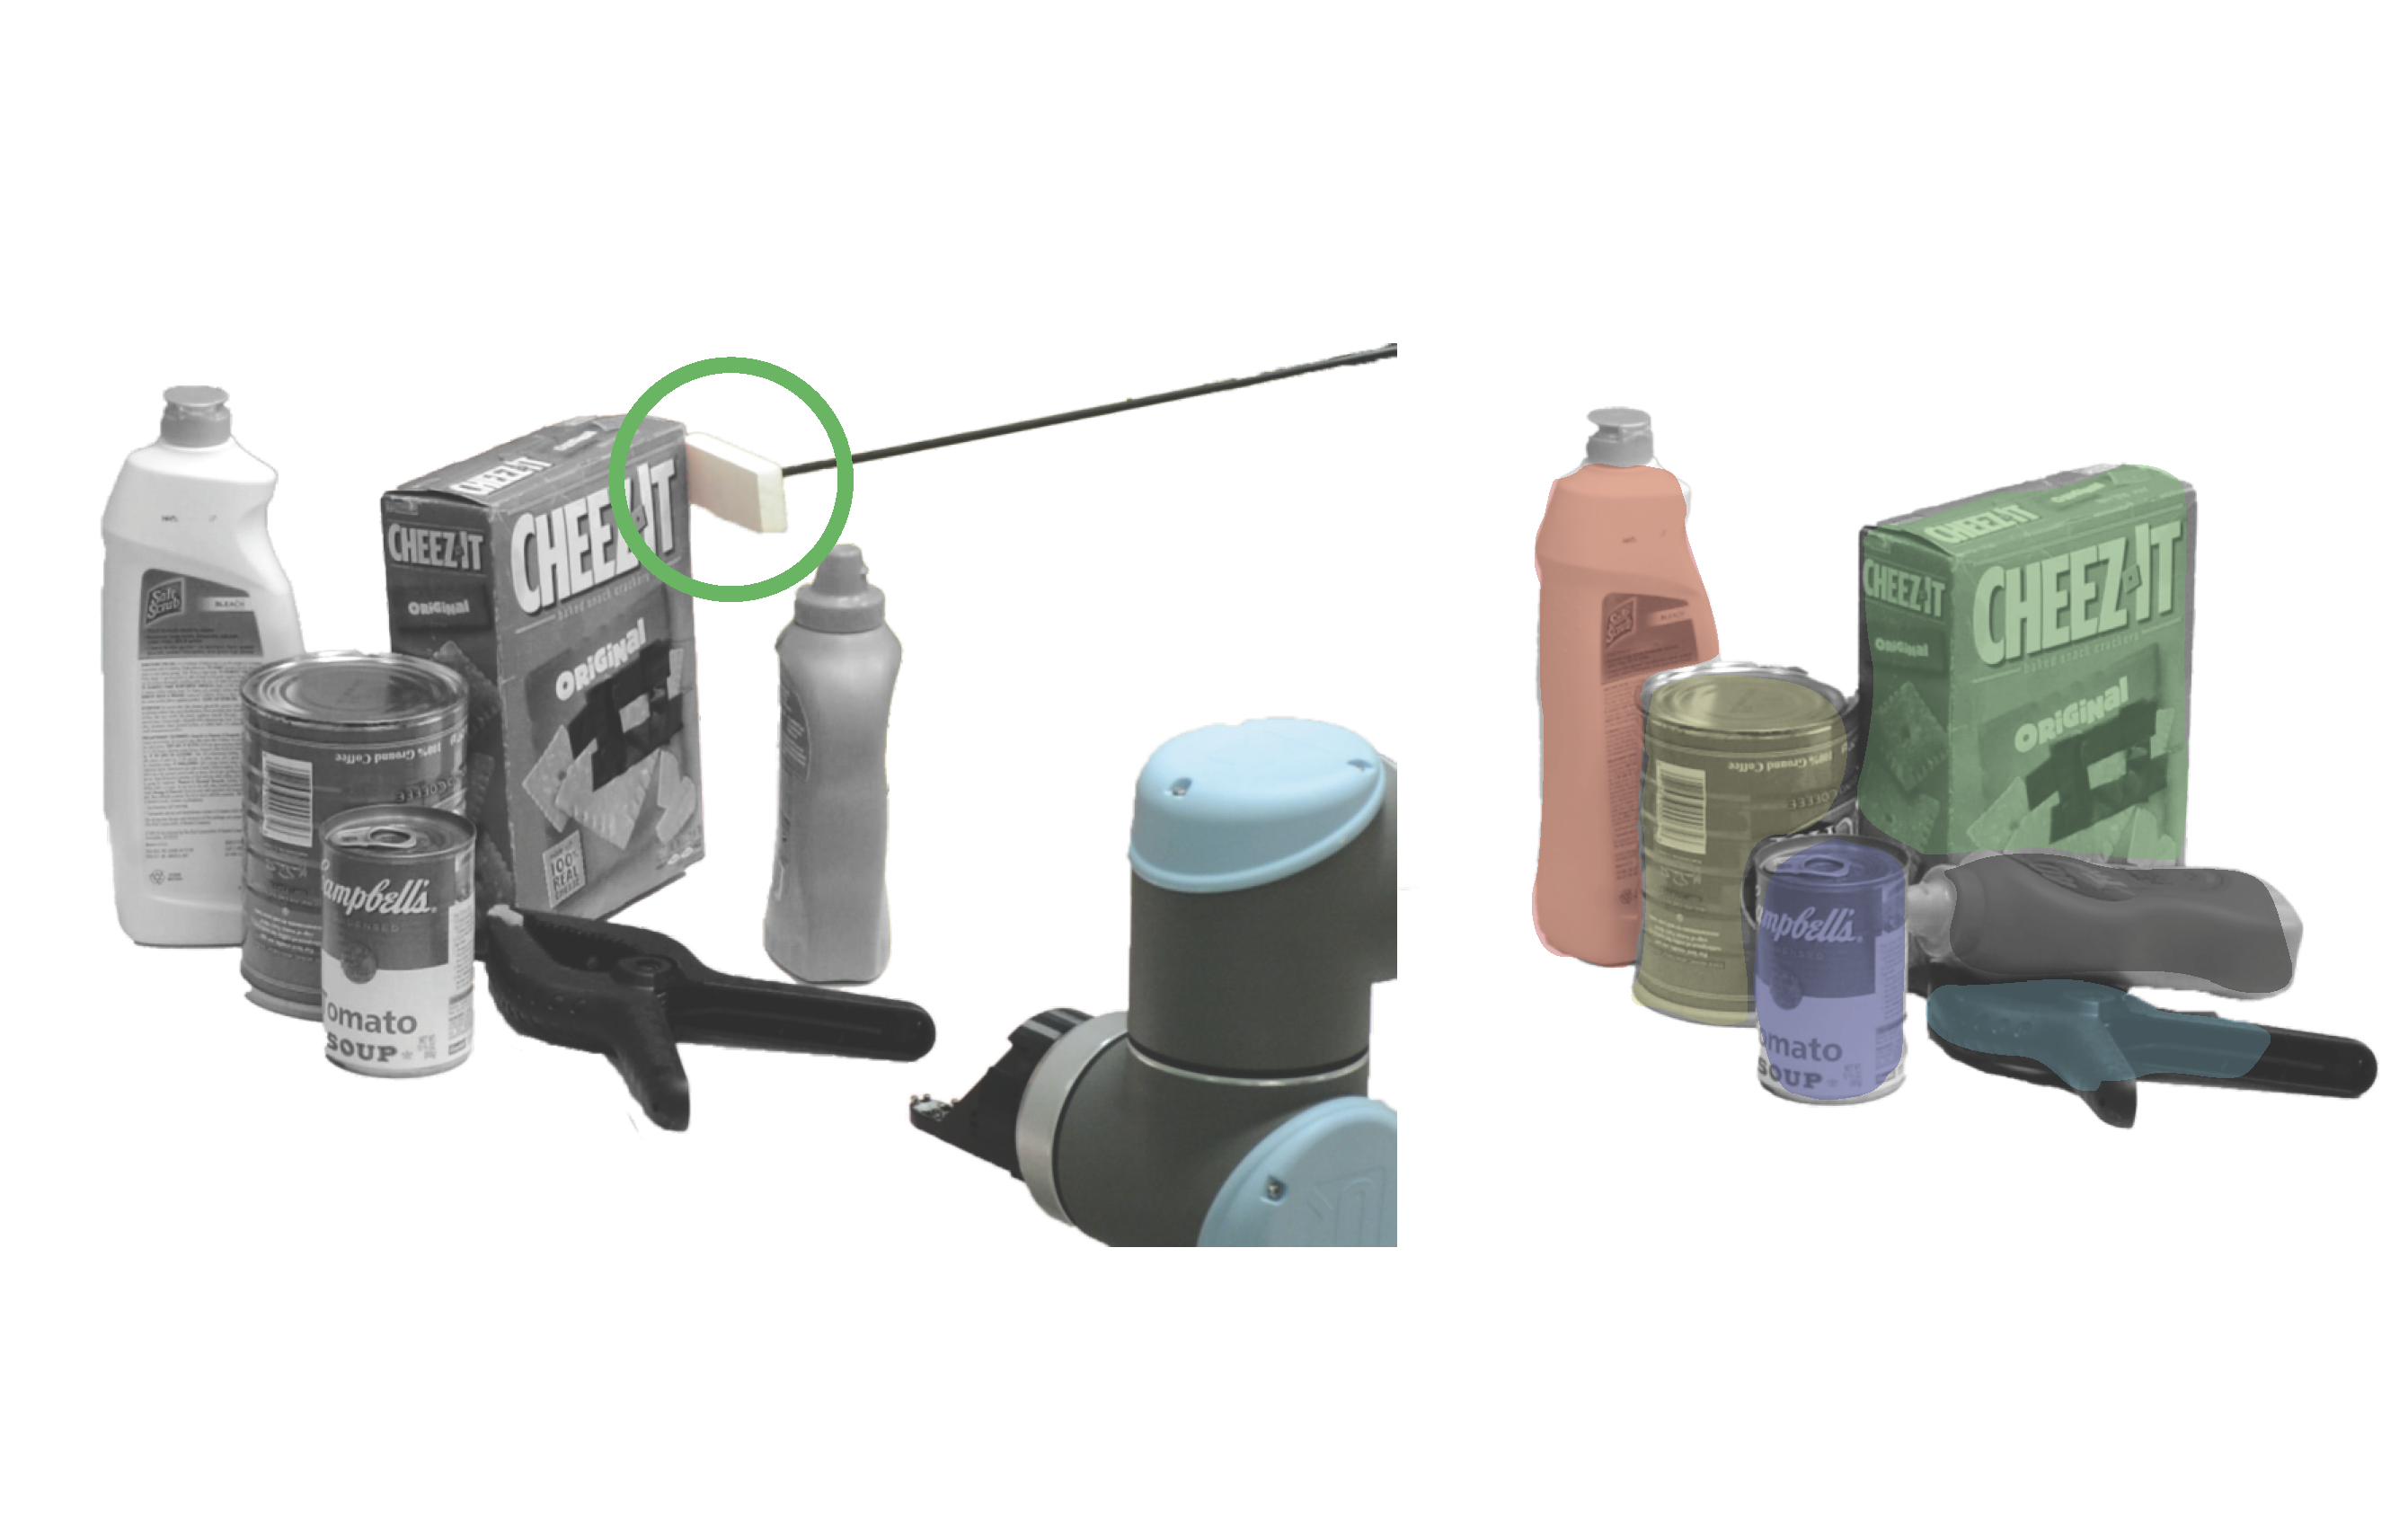
NudgeSeg: Zero-Shot Object Segmentation by Repeated Physical Interaction
IROS 2021
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
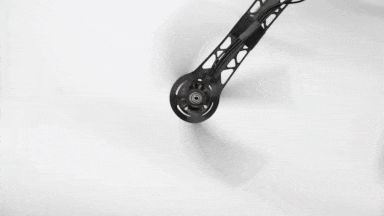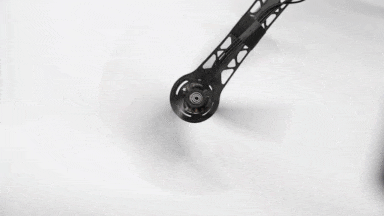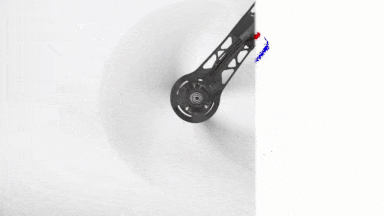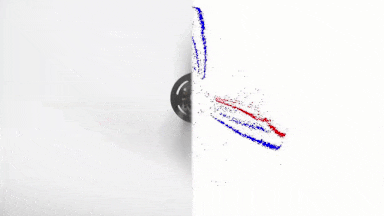
EVPropNet: Detecting Drones By Finding Propellers For Mid-Air Landing And Following
RSS 2021
Robotics: Science and Systems (RSS)
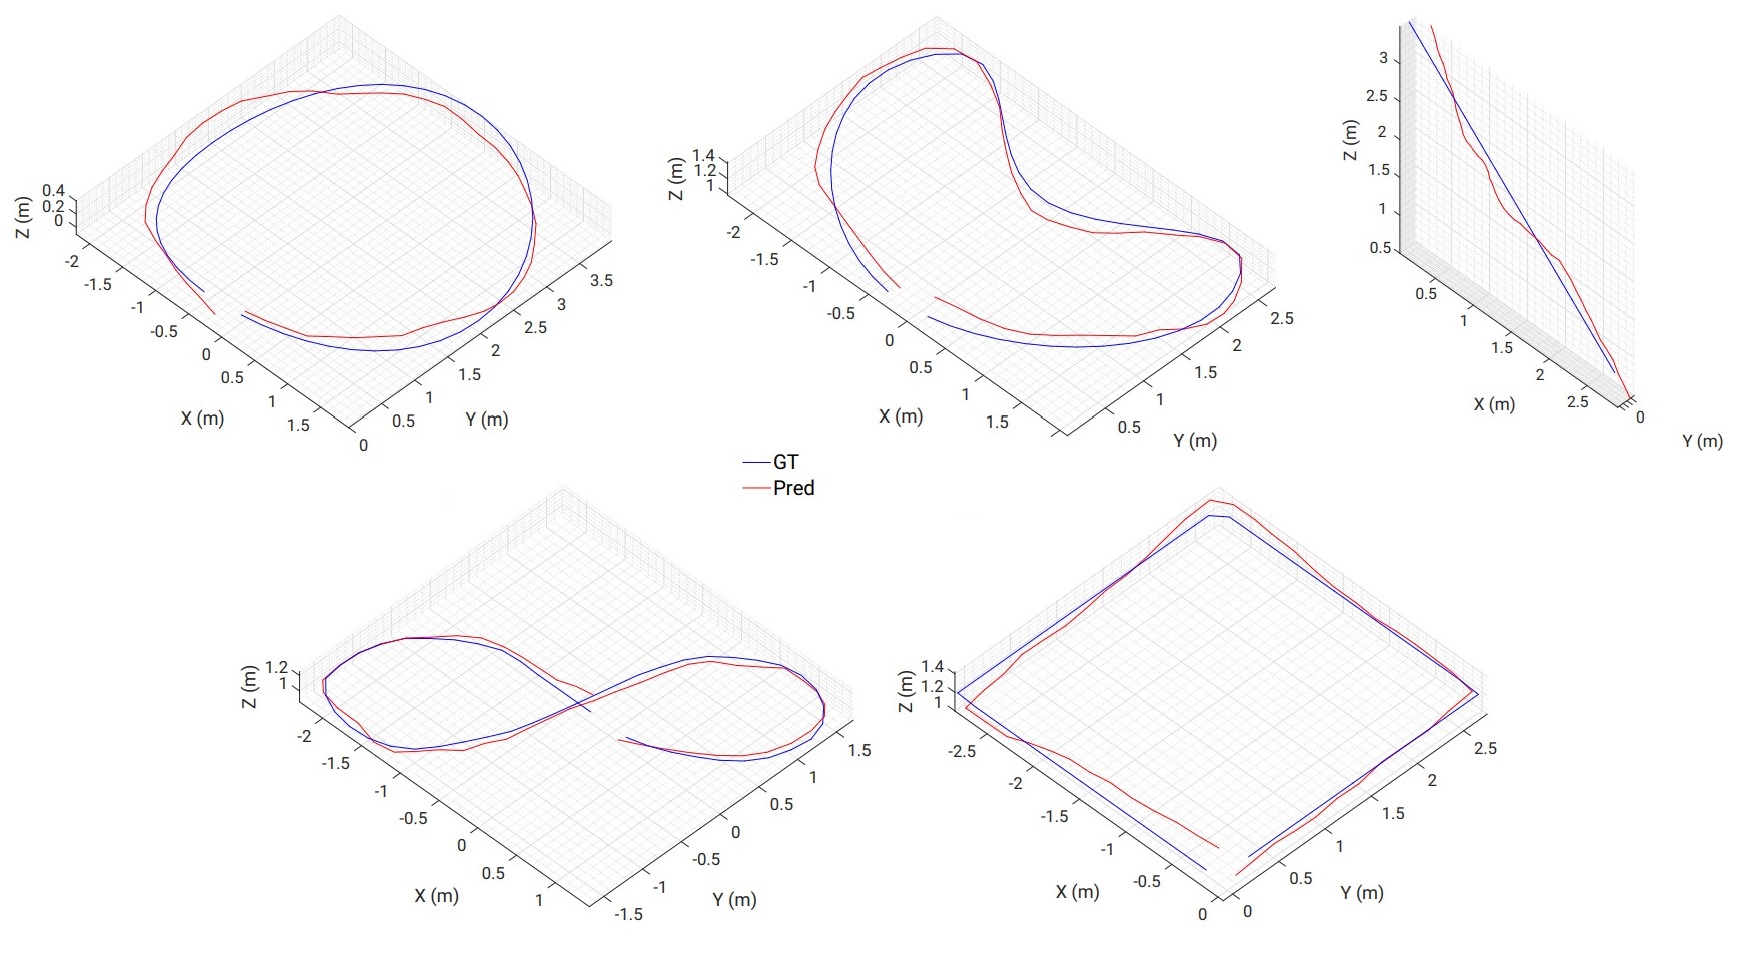
PRGFlow: Benchmarking SWAP-Aware Unified Deep Visual Inertial Odometry
IET Electronics Letters · 2021
Electronics Letters 57, no. 16 (2021): 614–617
0-MMS: Zero-Shot Multi-Motion Segmentation With A Monocular Event Camera
ICRA 2021
IEEE International Conference on Robotics and Automation
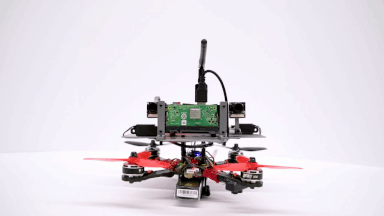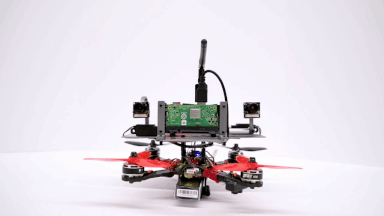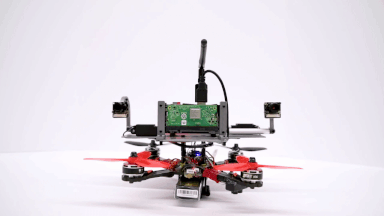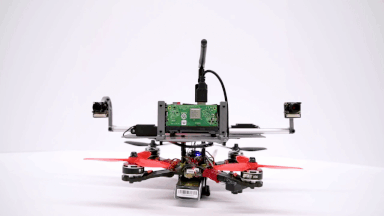
MorphEyes: Variable Baseline Stereo For Quadrotor Navigation
ICRA 2021
IEEE International Conference on Robotics and Automation
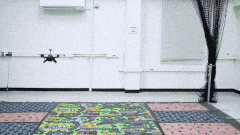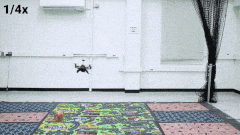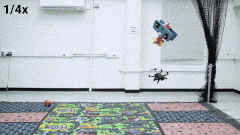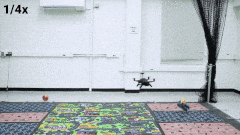
EVDodgeNet: Deep Dynamic Obstacle Dodging with Event Cameras
ICRA 2020
IEEE International Conference on Robotics and Automation
GapFlyt: Active Vision Based Minimalist Structure-less Gap Detection For Quadrotor Flight
RA-L 2018
IEEE Robotics and Automation Letters